• slidebg1
    SophyAI Digital Twins
  • slidebg1
    VR ROVER 5.0 PRO
  • slidebg1
    VR TRACTOR 5.0
  • slidebg1
    VR AXEL ROVER
  • slidebg1
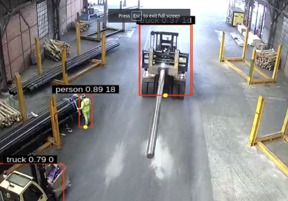
    SophyAI Mobile Anti Collision System
  • slidebg1
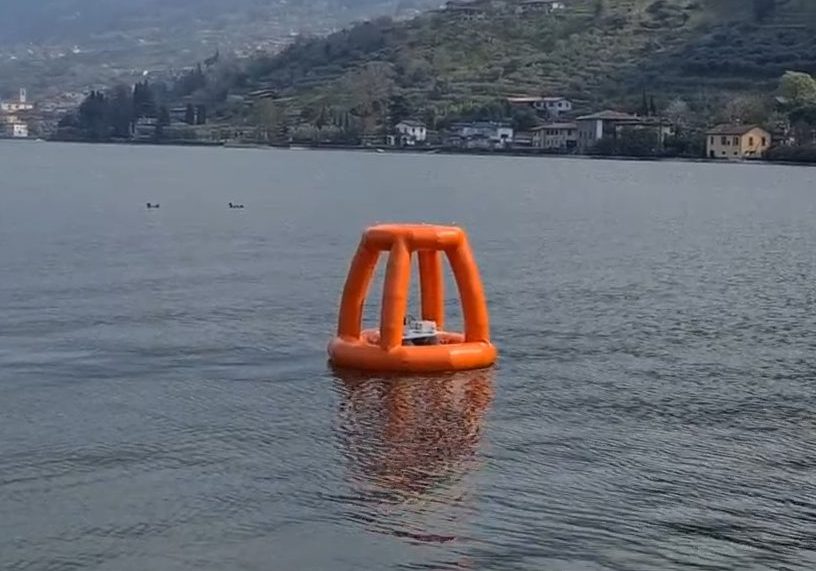
    Autonomous Robot Buoy
  • slidebg1
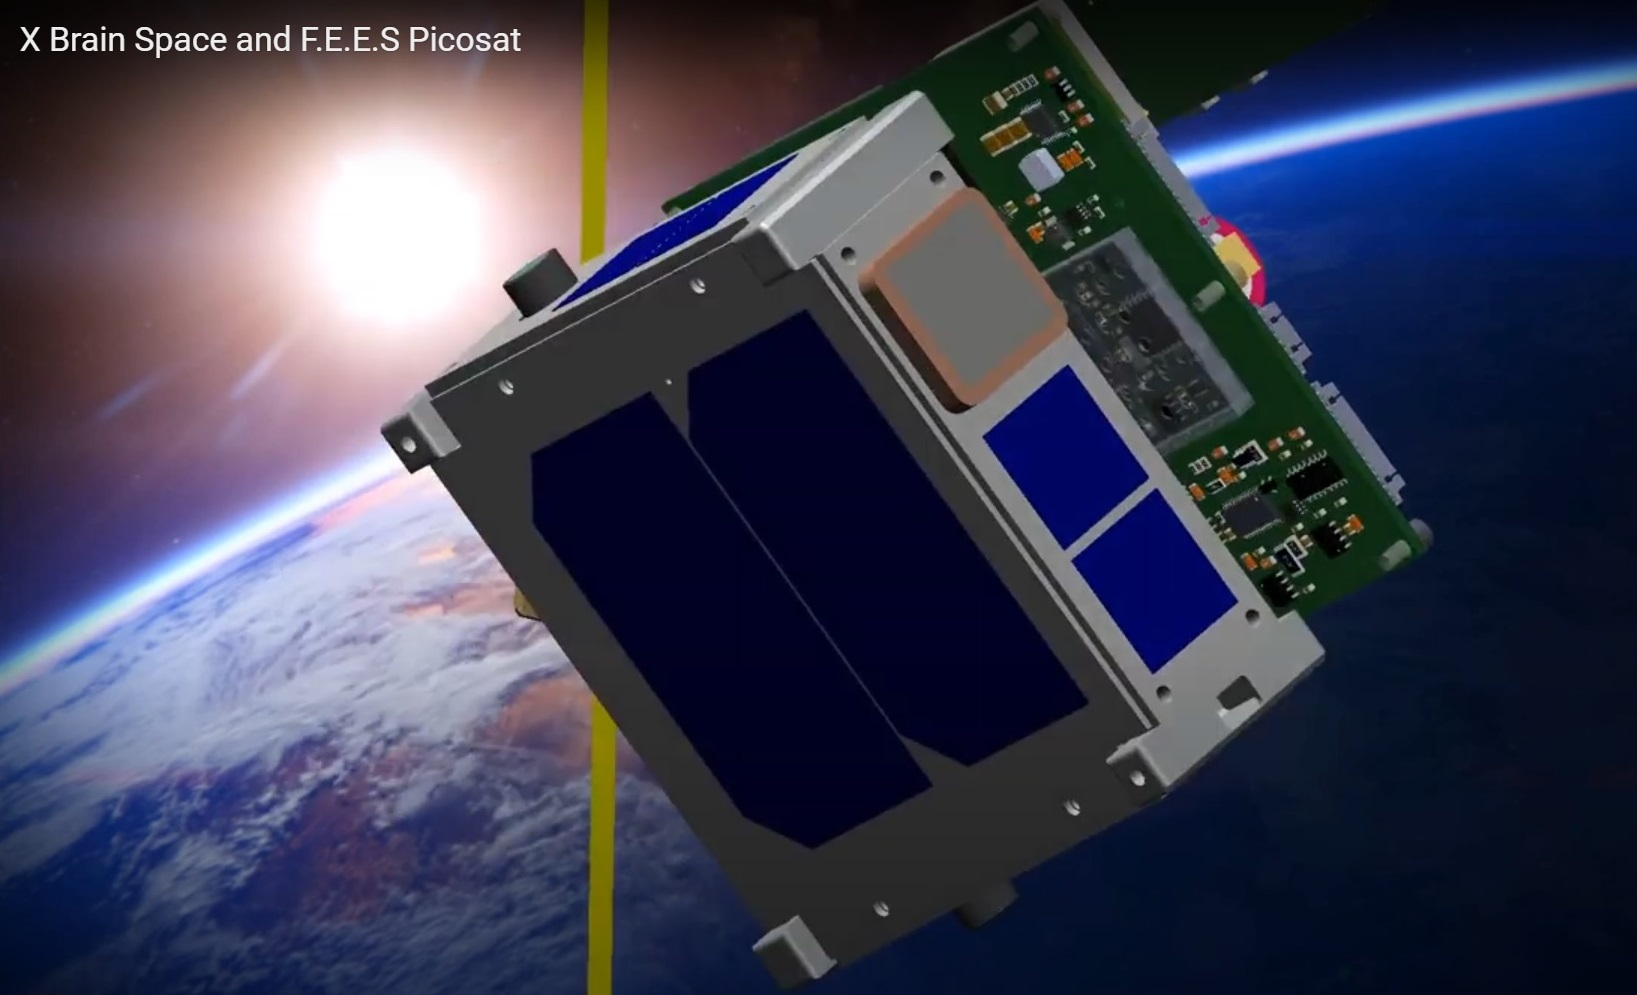
    SophyAI Space
 

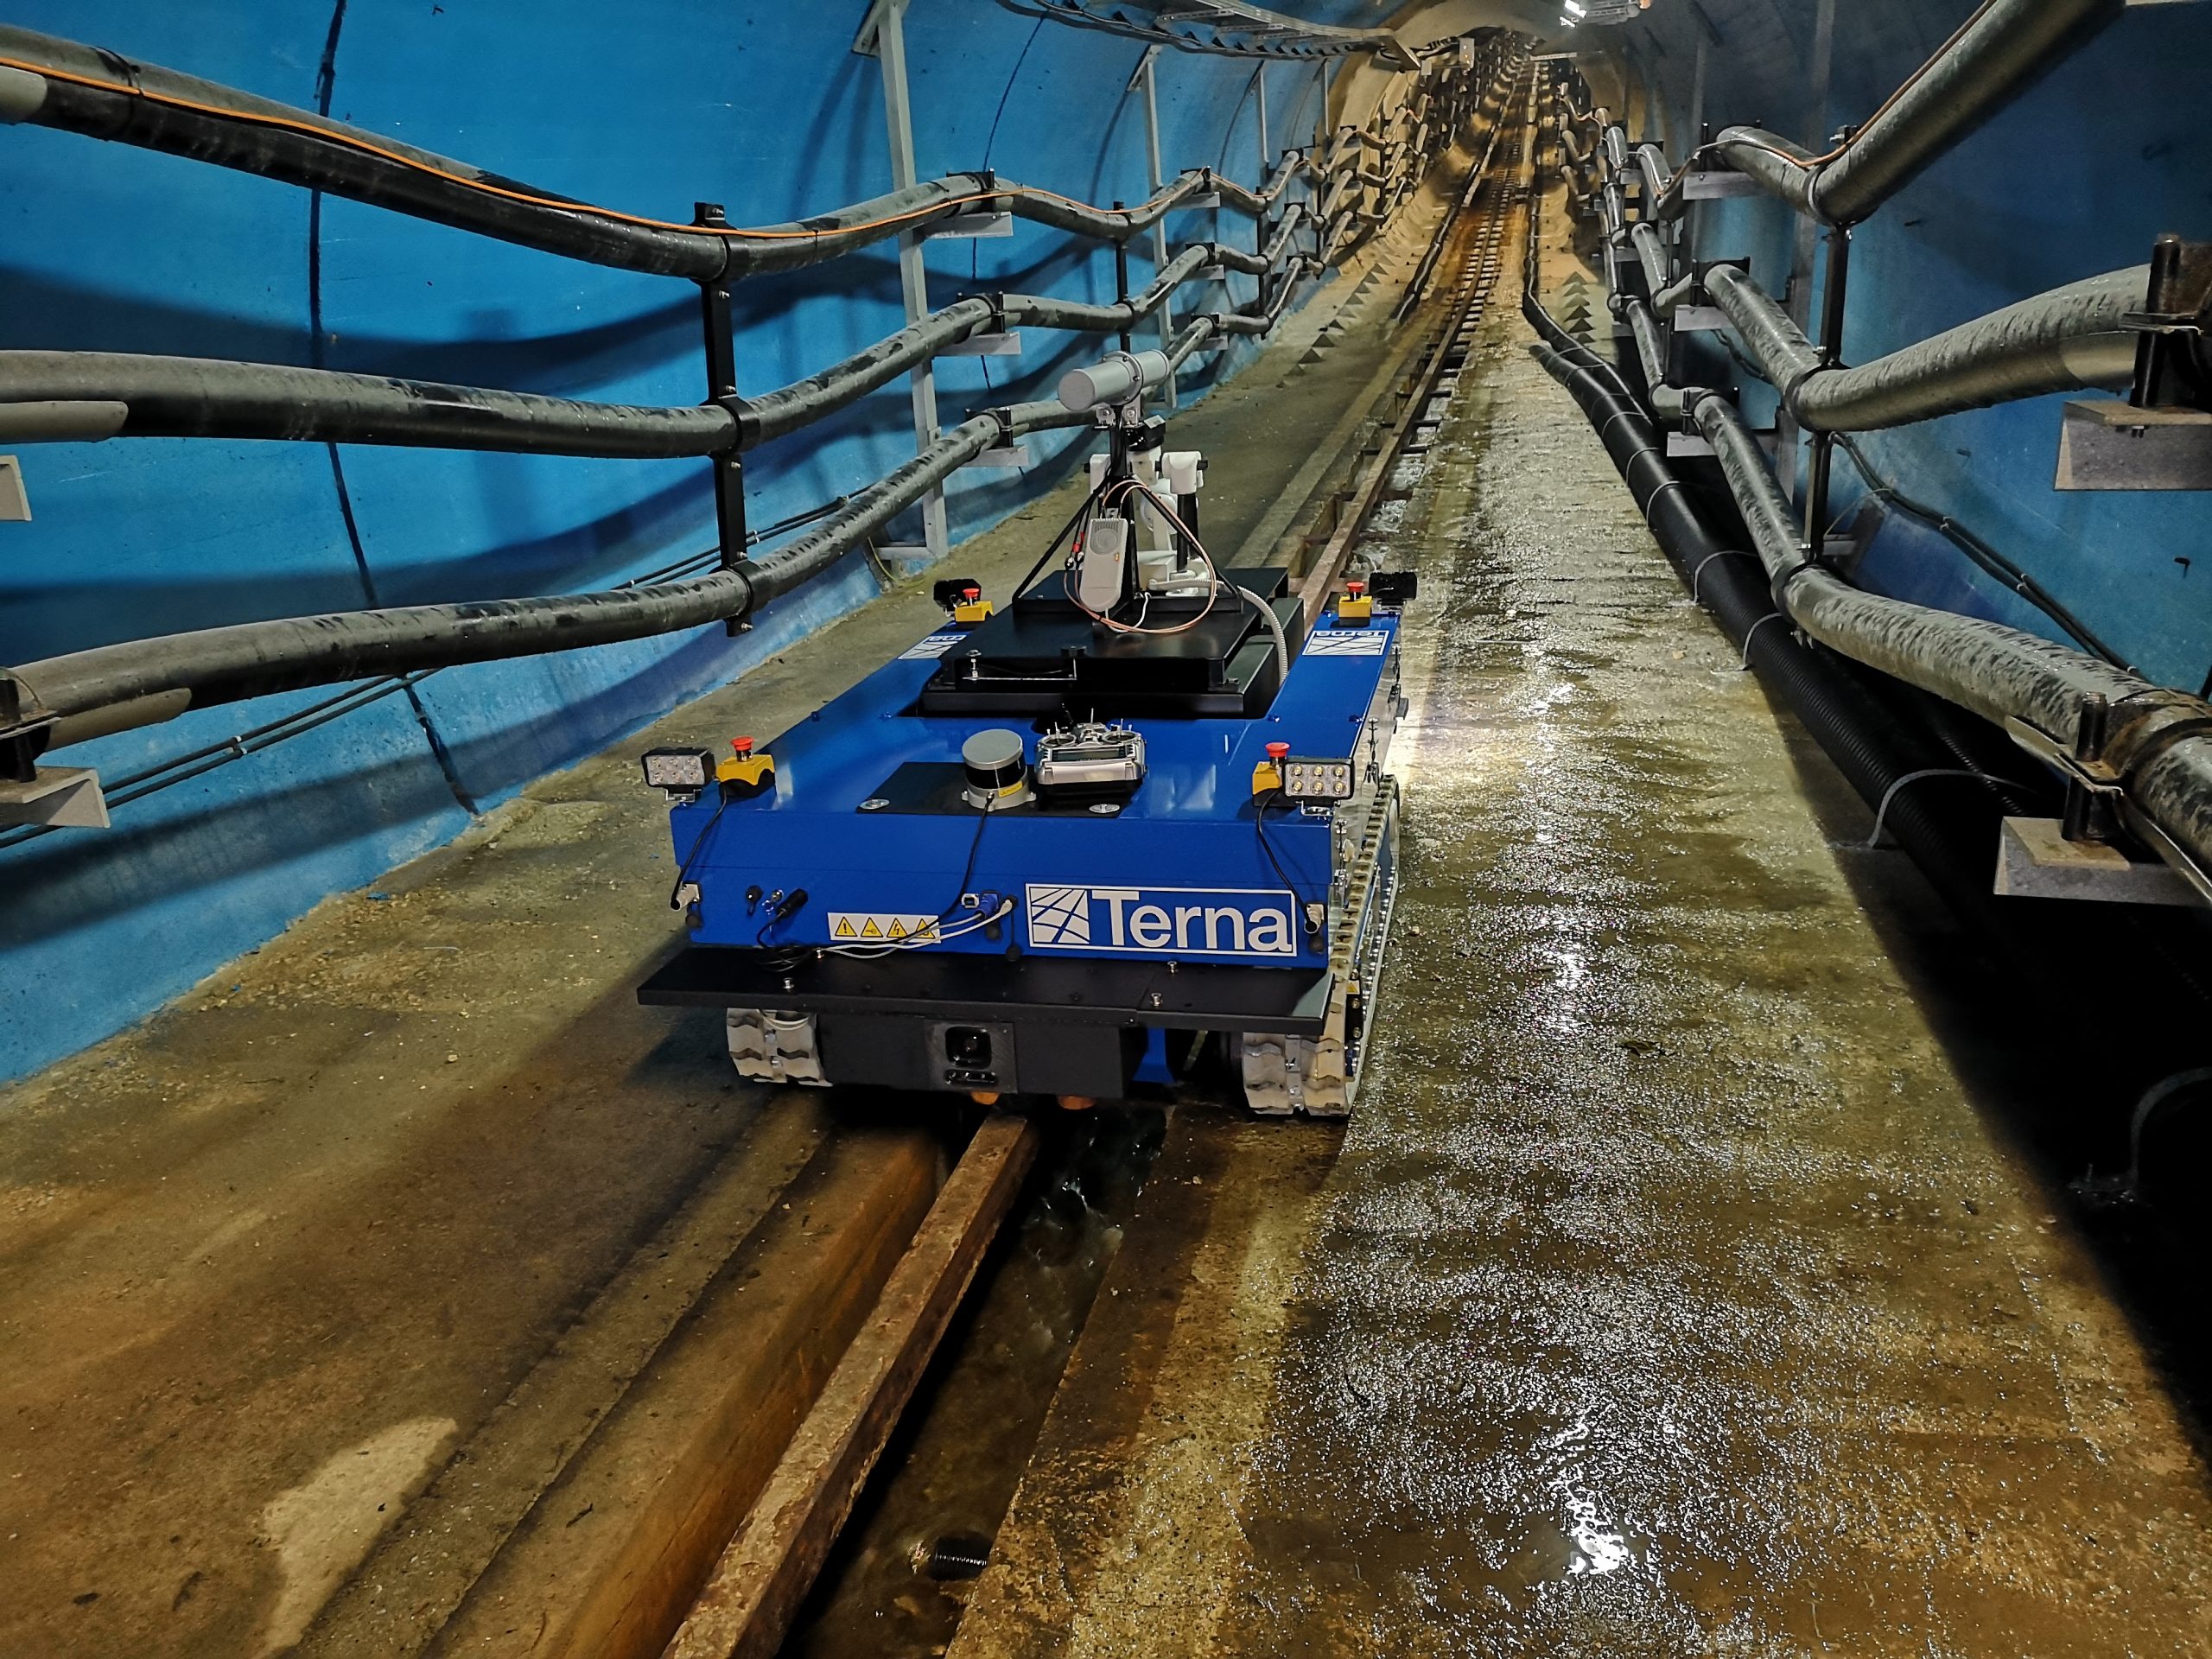
TERNA’s proposed challenge was to build an autonomously guided rover to carry out inspection and environmental condition testing operations in a tunnel with operating 380 KV circuit lines. It is certainly an environment where human presence is impossible when circuit lines are in operation but, given the presence of strong electromagnetic fields, also very hostile for a vehicle with sophisticated electronics in its payload. We have, with pride, managed to build a tracked rover that has met all the strict specifications imposed by TERNA. The rover is now in operation in the Favazzina tunnel and is performing its “operations” by moving and communicating the data collected by the sensors to our ground station outside the tunnel. Again, in our VR ROVER Autonomous Driving Modular Kit is the management and operational heart of the entire rover.

#ROBOTICS

Loader
Loading…
EAD Logo
Taking too long?
Reload Reload document

|

Open Open in new tab
Download [587.74 KB]

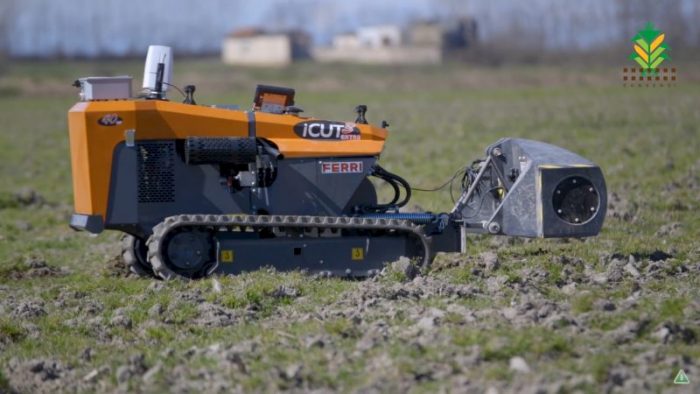
The scalability of the VR ROVER autonomous navigation platform allows for a version of it dedicated for use in agriculture. What we can call a “Kit” to be installed on any agricultural vehicle, allows it to be transformed into a remotely controllable vehicle or make it move autonomously by setting a predefined path. Of course, VR ROVER maintains its main functions such as anti-collision and the ability to set and control remotely, via the Can-Bus of the vehicle, the parameters necessary for the control of its motility and the performance of operations by the equipment on the vehicle itself.

#ROBOTICS

Loader
Loading…
EAD Logo
Taking too long?
Reload Reload document

|

Open Open in new tab
Download [379.90 KB]


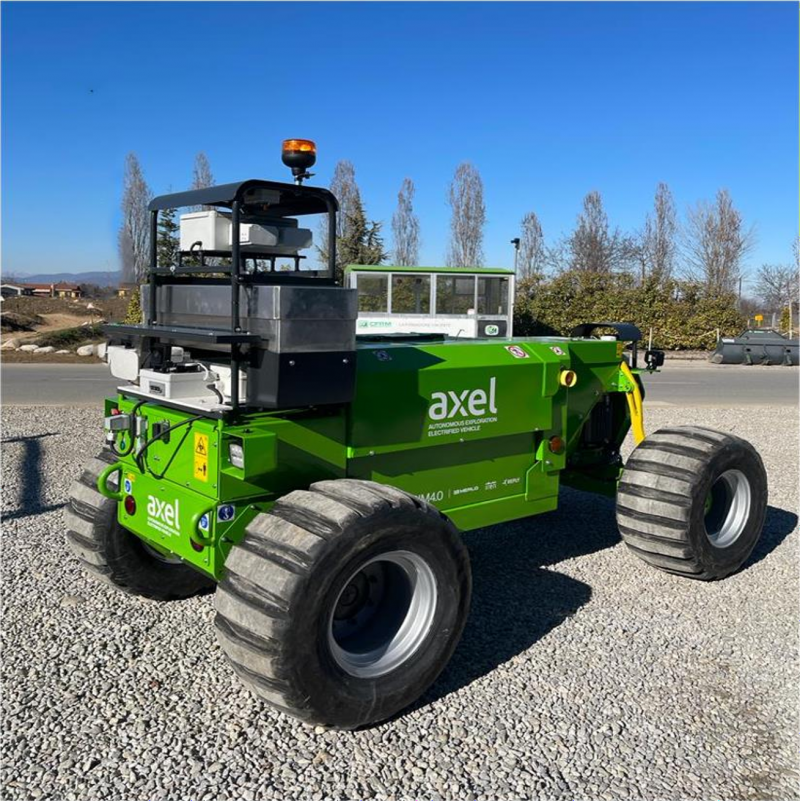
Laser designed and realized for Webuild and CIM 4.0 the remote navigation component, communication/vision system and ground station of the Axel unmanned rover. The application of our modular VR Rover autonomous navigation platform enabled the vehicle to be fully autonomous and connected.Axel’s main function is to monitor, through sensors, the environmental conditions inside tunnels, detecting, in addition to temperature and humidity, several harmful gases to be certain that their concentrations are not harmful to workers performing tunnel work. AXEL Rover is operational in the advancement of tunnel work on the Turin Lyon.

#ROBOTICS

Loader Loading…
EAD Logo Taking too long?
Reload Reload document
| Open Open in new tab
Download [0.98 MB]

Latest News

Our Customer & Partner